
 Contacto
 Cómo comprar

Entrega
Guía de compras
 Inglés
 597 b
Hasta 30 días para devoluciones
Clientes que también han comprado


 /
 Tapa dura
 31.19
€


 /
Tapa blanda
7.59
€






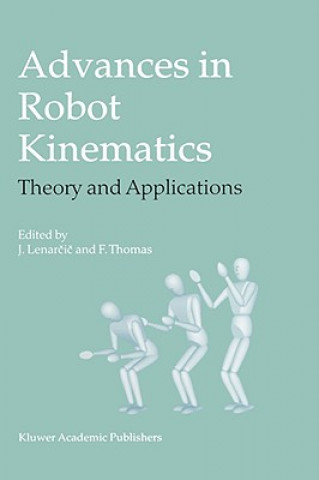
This book presents the most recent research advances in the theory, design, control and application of robotic systems, which are intended for a variety of purposes such as manipulation, manufacturing, automation, surgery, locomotion, and biomechanics. The issues addressed are fundamentally kinematic in nature, including synthesis, calibration, redundancy, force control, dexterity, inverse and forward kinematics, kinematic singularities, as well as over-constrained systems. Methods used include line geometry, quaternion algebra, screw algebra, and linear algebra. These methods are applied to both parallel and serial multi-degree-of-freedom systems. The results should interest researchers, teachers and students, in fields of engineering and mathematics related to robot theory, design, control and application.


Sobre el libro
Inglés
Categorías

Regale este libro hoy
Es fácil
1 Añadir al carrito y elegir Entregar como regalo en el checkout 2 Le enviaremos un vale 3 El libro llegará a la dirección del destinatarioTambién puede interesarle
 /
Tapa blanda
225.39
€
 /
Tapa blanda
13.79
€


 /
Tapa blanda
32.69
€


 /
Tapa dura
31.29
€


 /
Tapa blanda
10.99
€


 /
Tapa blanda
29.59
€




¡Hola! Soy Libroamiko, tu asesor de libros.
¿Cómo puedo ayudarte?