
 Contacto
 Cómo comprar

Entrega
Guía de compras
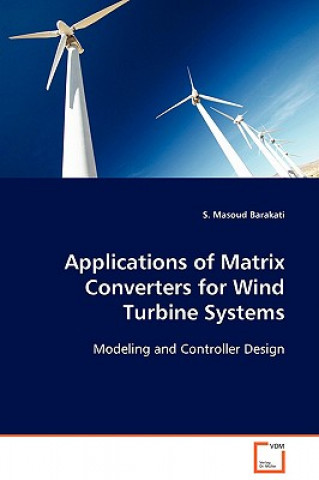
Applications of Matrix Converters for Wind Turbine Systems
 Inglés
 208 b
Hasta 30 días para devoluciones
Clientes que también han comprado



 /
 Tapa blanda
 26.49
€
 /
Tapa blanda
14.89
€
 /
Tapa blanda
195.89
€

A grid-connected wind-energy converter system §including a matrix converter (MC) is proposed. Two §dynamic models are addressed: MC dynamic model, and §proposed wind turbine system overall model. The MC §dynamic model is valid for both steady-state and §transient analyses. In developing the system overall §dynamic model, individual models of the aerodynamic §conversion, drive train, MC, and induction generator §are developed. The constraint constant V/f strategy §is included in the final dynamic model. The model is §intended to be useful for controller design §purposes. The model dynamic behavior is investigated §by simulating the response of the overall model to §step changes in selected input variables. Moreover, §a linearized model is developed at a typical §operating point, and stability, controllability, and §observability of the system are investigated. Two §control design methods are adopted for the design of §the closed-loop controller: a state-feedback §controller and an output feedback controller. §Finally, a maximum power point tracking method, §referred to as mechanical speed-sensorless power §signal feedback, is developed for the system. A grid-connected wind-energy converter system §including a matrix converter (MC) is proposed. Two §dynamic models are addressed: MC dynamic model, and §proposed wind turbine system overall model. The MC §dynamic model is valid for both steady-state and §transient analyses. In developing the system overall §dynamic model, individual models of the aerodynamic §conversion, drive train, MC, and induction generator §are developed. The constraint constant V/f strategy §is included in the final dynamic model. The model is §intended to be useful for controller design §purposes. The model dynamic behavior is investigated by simulating the response of the overall model to §step changes in selected input variables. Moreover, §a linearized model is developed at a typical §operating point, and stability, controllability, and §observability of the system are investigated. Two §control design methods are adopted for the design of §the closed-loop controller: a state-feedback §controller and an output feedback controller. §Finally, a maximum power point tracking method, §referred to as mechanical speed-sensorless power §signal feedback, is developed for the system.


Sobre el libro
Inglés

Regale este libro hoy
Es fácil
1 Añadir al carrito y elegir Entregar como regalo en el checkout 2 Le enviaremos un vale 3 El libro llegará a la dirección del destinatarioTambién puede interesarle


 /
Tapa blanda
30.89
€


 /
Tapa blanda
29.49
€
 /
Tapa blanda
29.89
€
¡Hola! Soy Libroamiko, tu asesor de libros.
¿Cómo puedo ayudarte?